Autonomous robotics · Third Prize
FAST Maze Runner
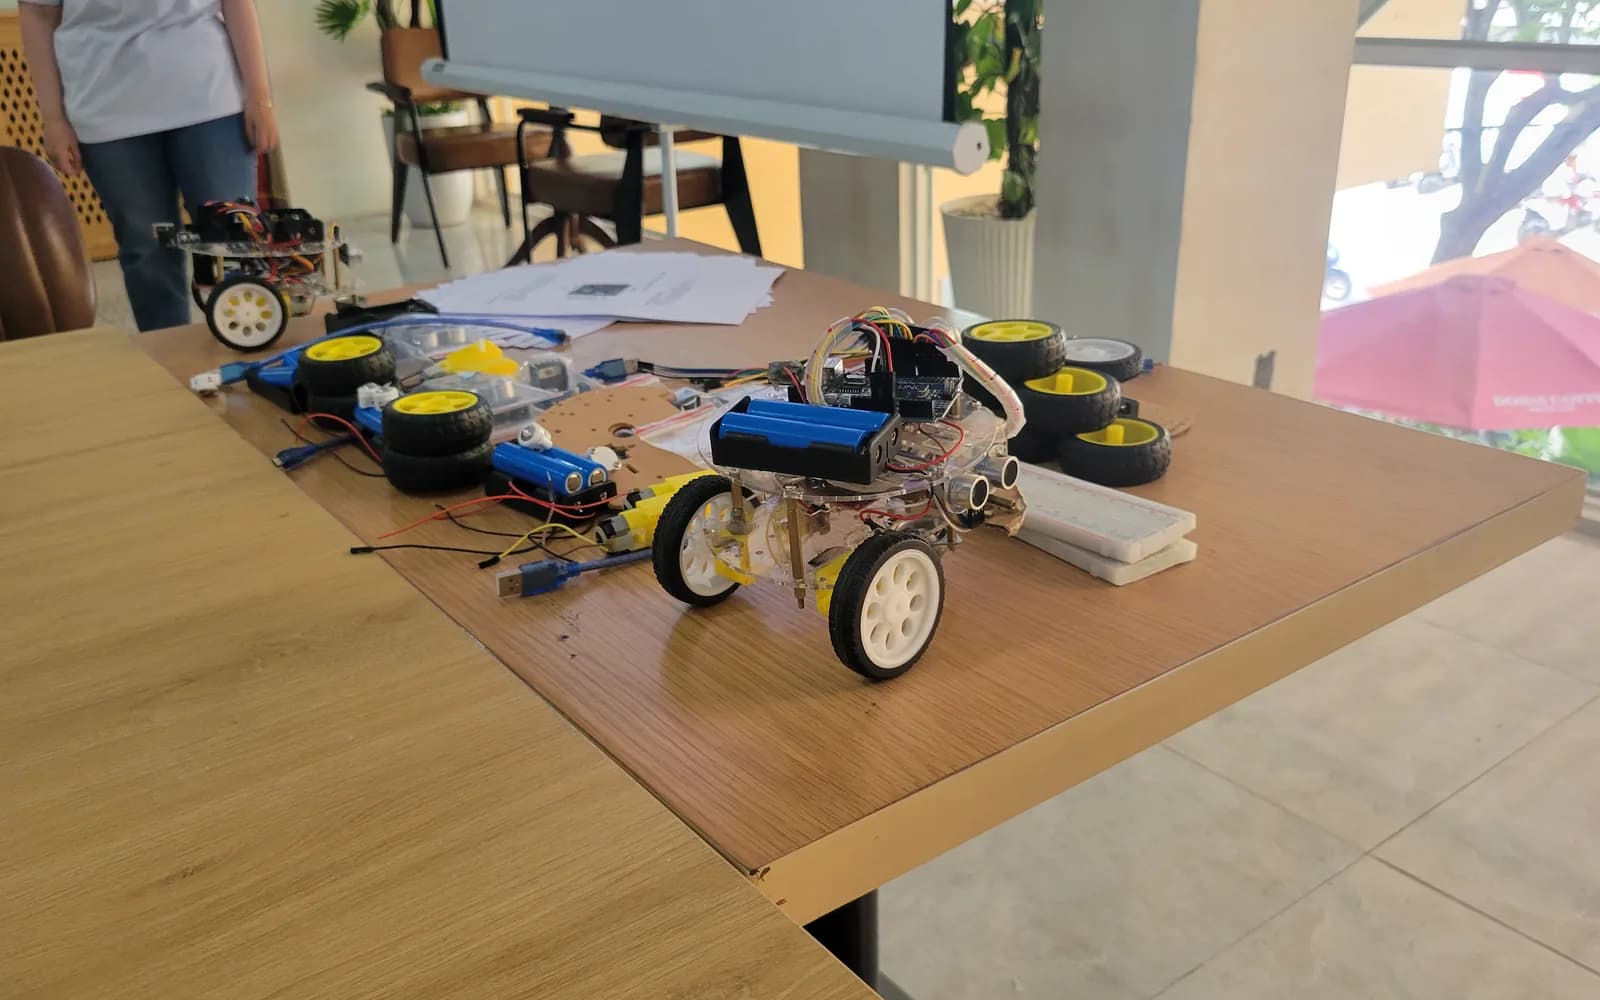
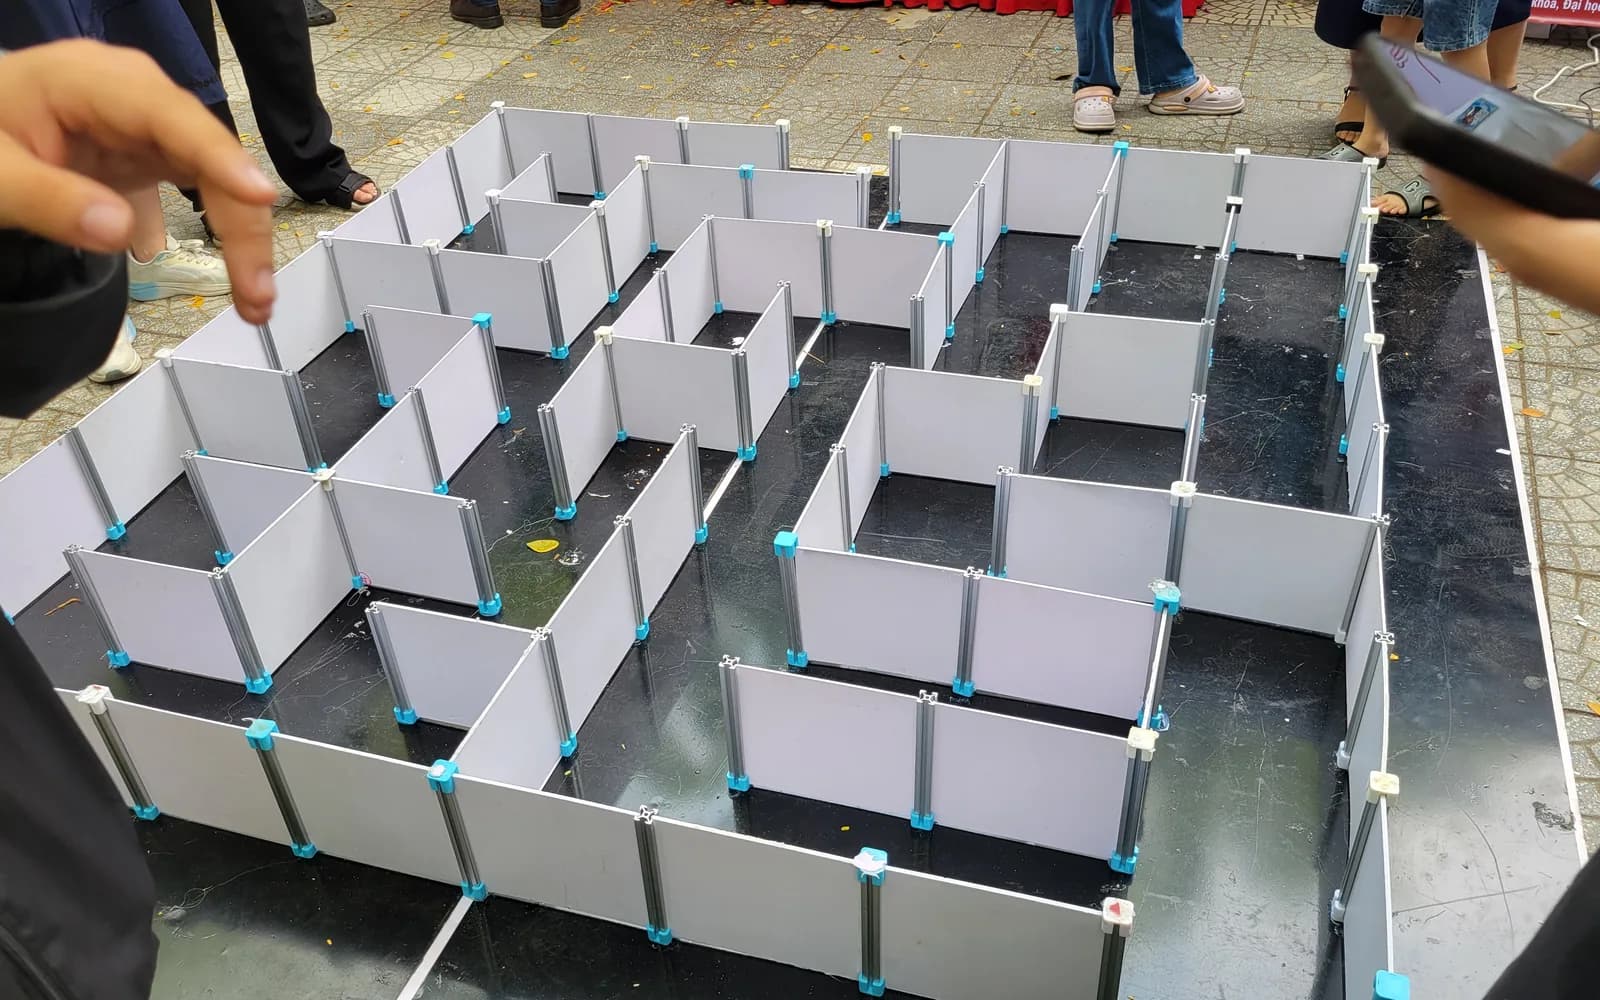
An autonomous maze-solving differential-drive robot utilizing ultrasonic sensor arrays, dedicated power regulation, and dynamic pathfinding algorithms to solve unmapped mazes.
- Role
- Robotics Team Lead · The Physicians
- When
- April 2025
- Mode
- Physical systems
01 / Context
The problem
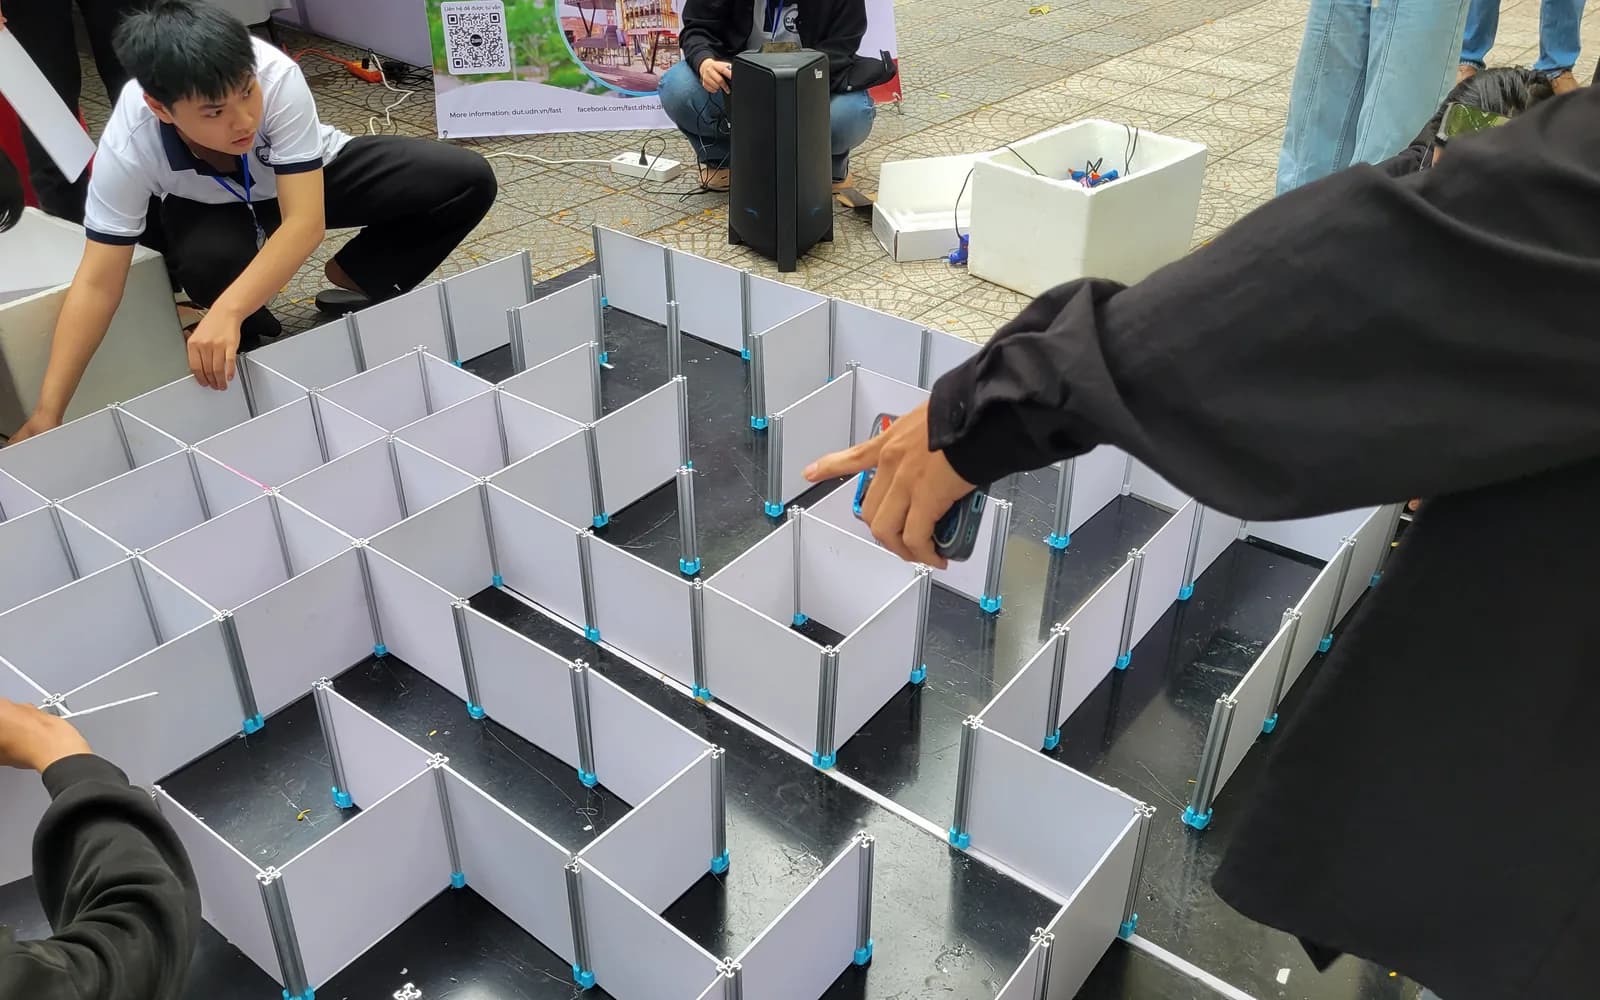
Solving an unmapped physical labyrinth requires real-time sensing, precise turning actuation, and collision-free path decision logic under aggressive battery and timing constraints.
Approach
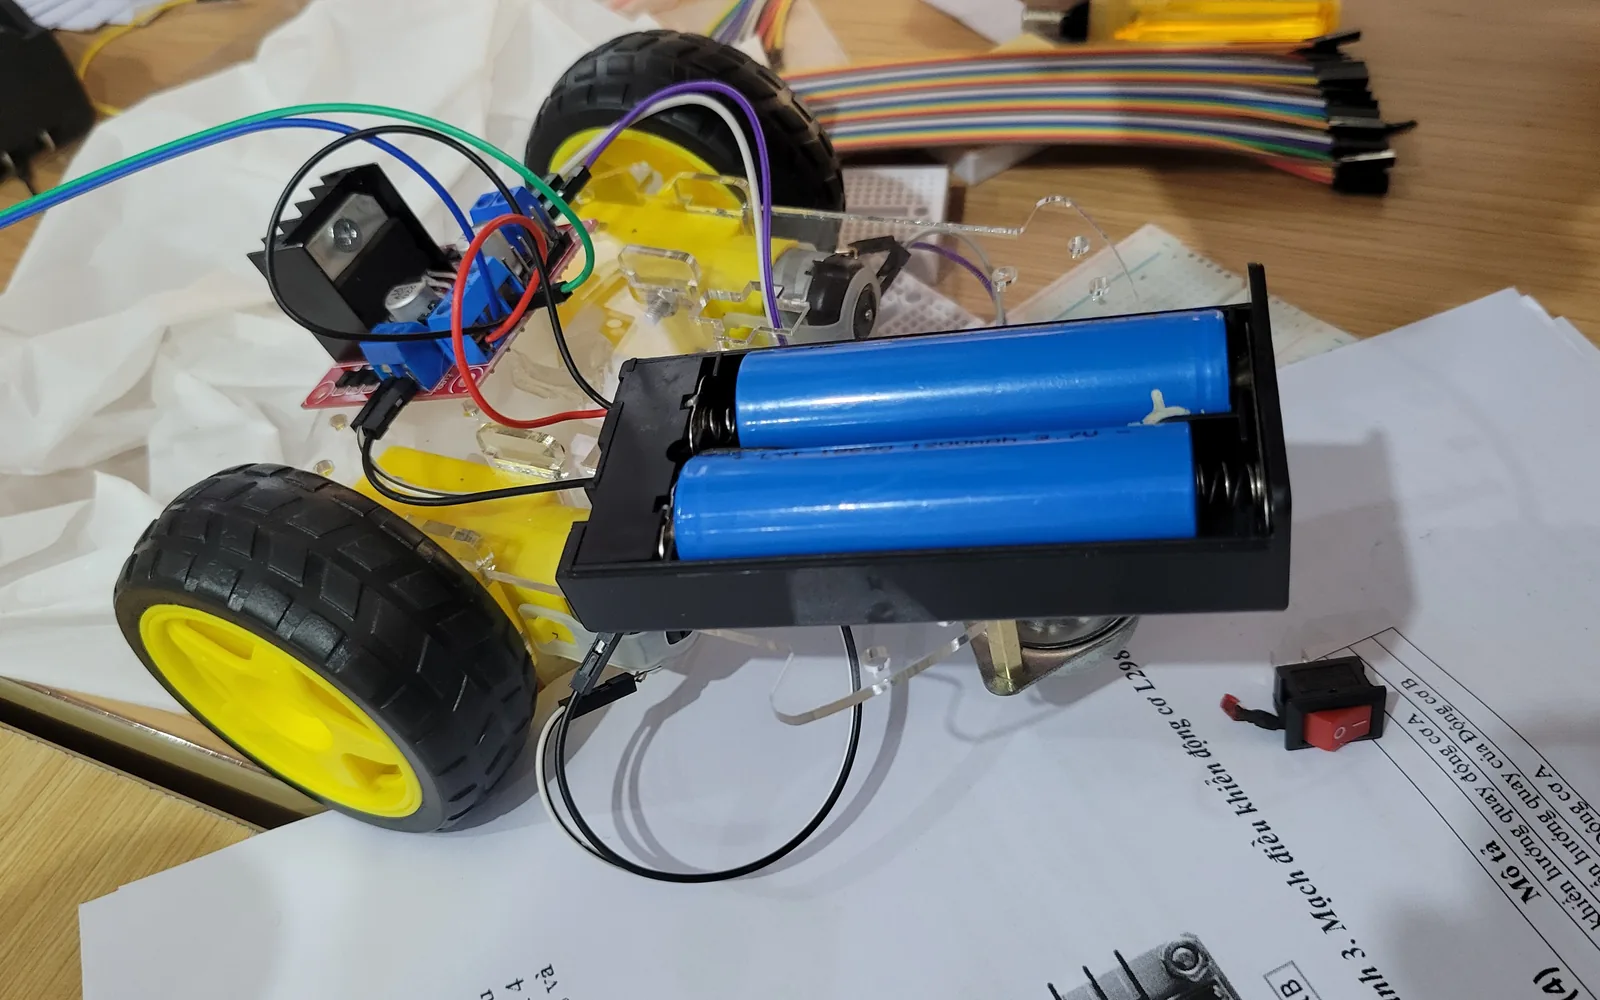
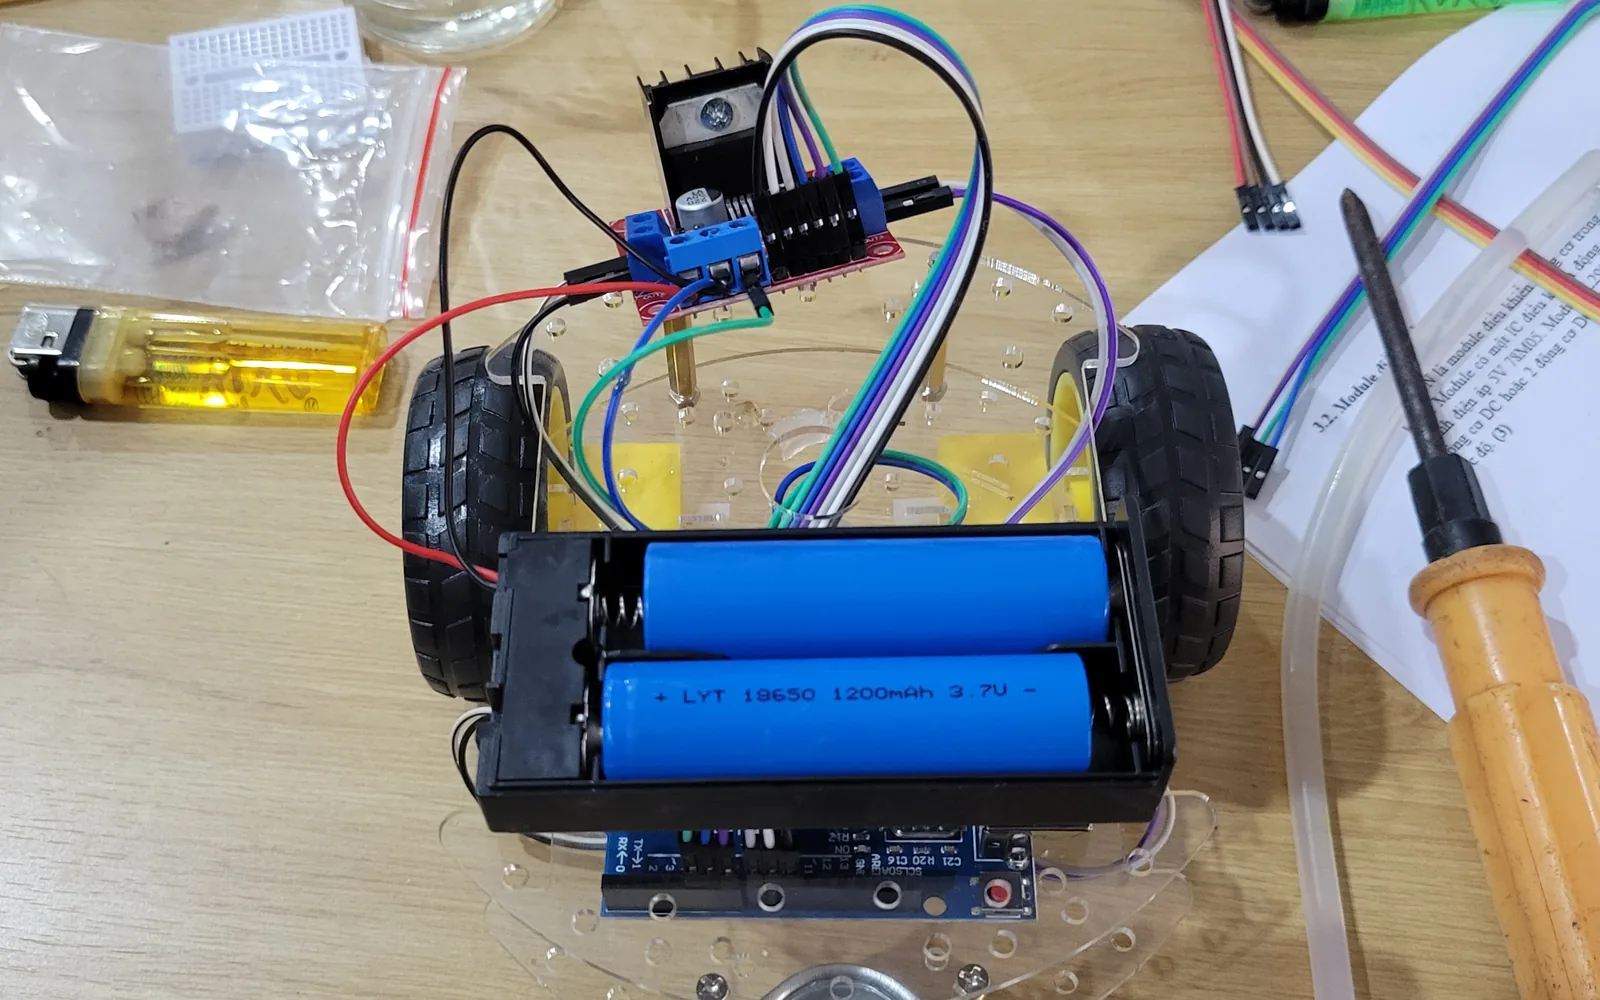
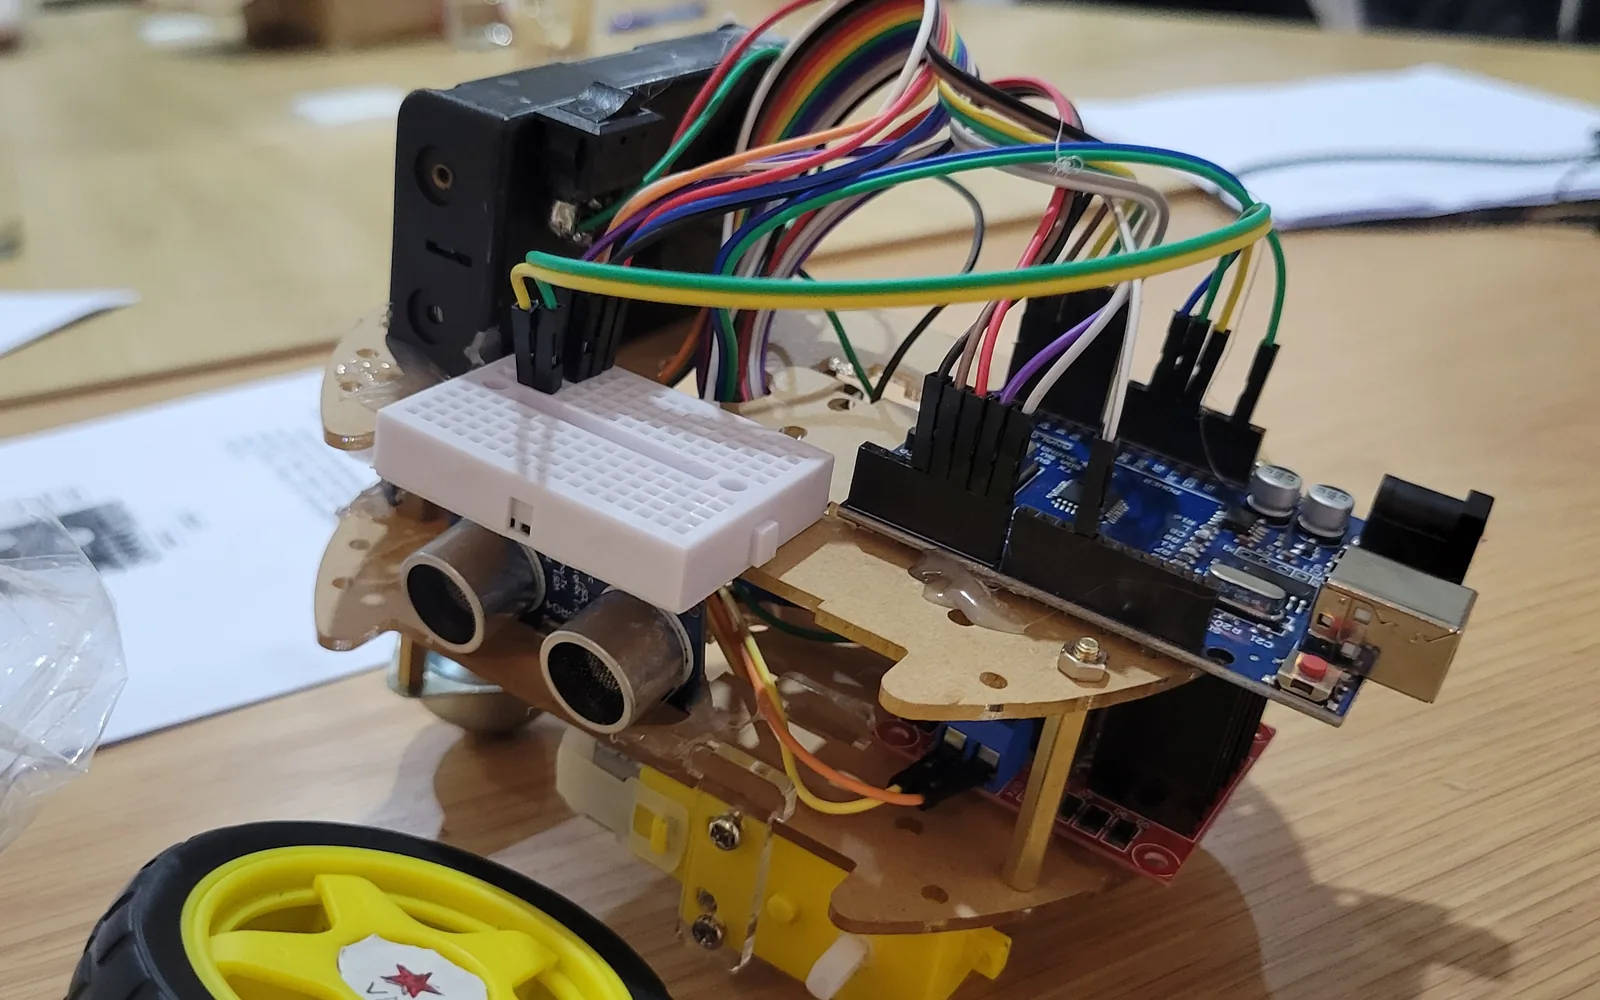
Our team built a differential-drive robot chassis with an Arduino controller, high-torque geared motors, and three ultrasonic sensors. The control software samples obstacle clearances, detects wall junctions, and executes a modified wall-following and junction-priority traversal algorithm.
02 / Contribution
What I contributed
- 01
Led Team “The Physicians” across hardware integration, electronic testing, and competition trials.
- 02
Designed the multi-sensor placement layout and motor driver wiring to eliminate electromagnetic noise.
- 03
Developed and calibrated the maze exploration and junction-selection state machine in C++.
- 04
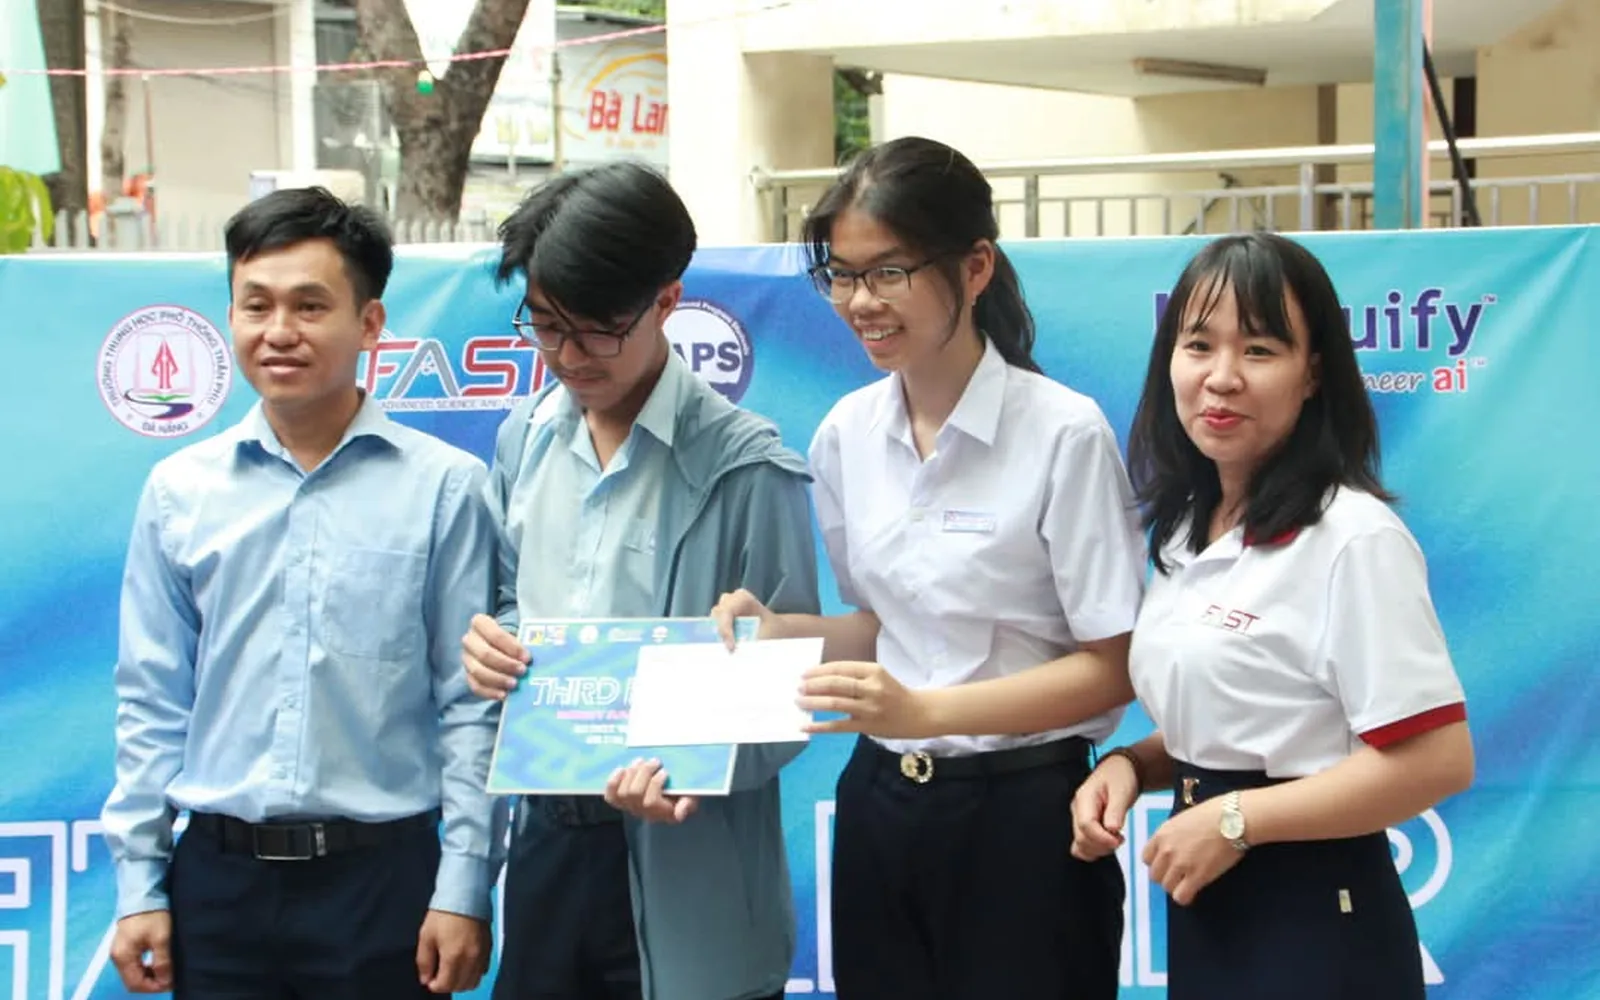
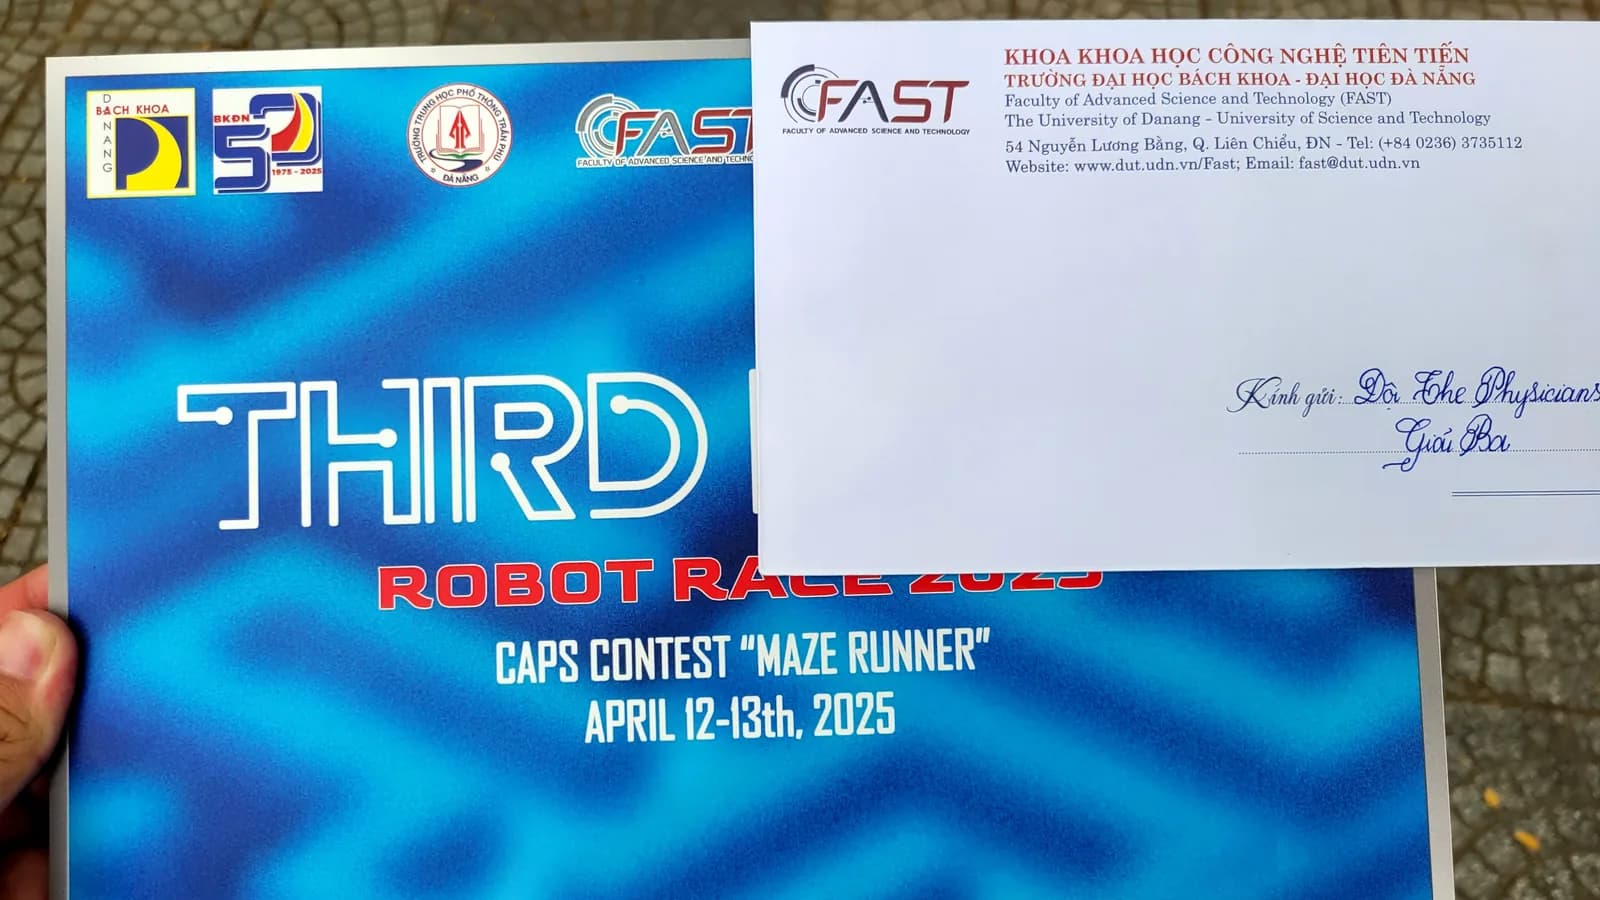
Secured Third Prize at the FAST Robotics Maze Solver Challenge 2025 at Danang University of Technology.
03 / Decisions
Technical decisions
Separate motor and logic power
Used dual power lines and filtering capacitors to prevent MCU brownout resets when DC motors draw peak current during quick turns.
Three-point sensor array
Positioned front, left, and right ultrasonic sensors at 45-degree angled axes to detect diagonal corridors before committing to turns.
Dynamic speed throttling
Reduced forward drive speed when corridor margins narrowed below safe thresholds to maintain heading accuracy.
04 / Project gallery
Evidence, interfaces, and process.
05 / Evidence
Outcome
- Awarded Third Prize at FAST Robotics Maze Solver Challenge 2025.
- Achieved zero collision faults across all official competition runs.
- Validated end-to-end autonomous navigation combining physical assembly, sensing, and real-time control.